SAR-SLAM: Semantic-Aware Recognition for Dynamic SLAM in Robotic Applications
SAR-SLAM is an RGB-D SLAM framework that combines semantic detection with geometric verification to distinguish stationary from moving objects, reducing Absolute Trajectory Error by up to 96% compared to ORB-SLAM3 on the TUM benchmarks.
SAR-SLAM: Semantic-Aware Recognition for Dynamic SLAM in Robotic Applications
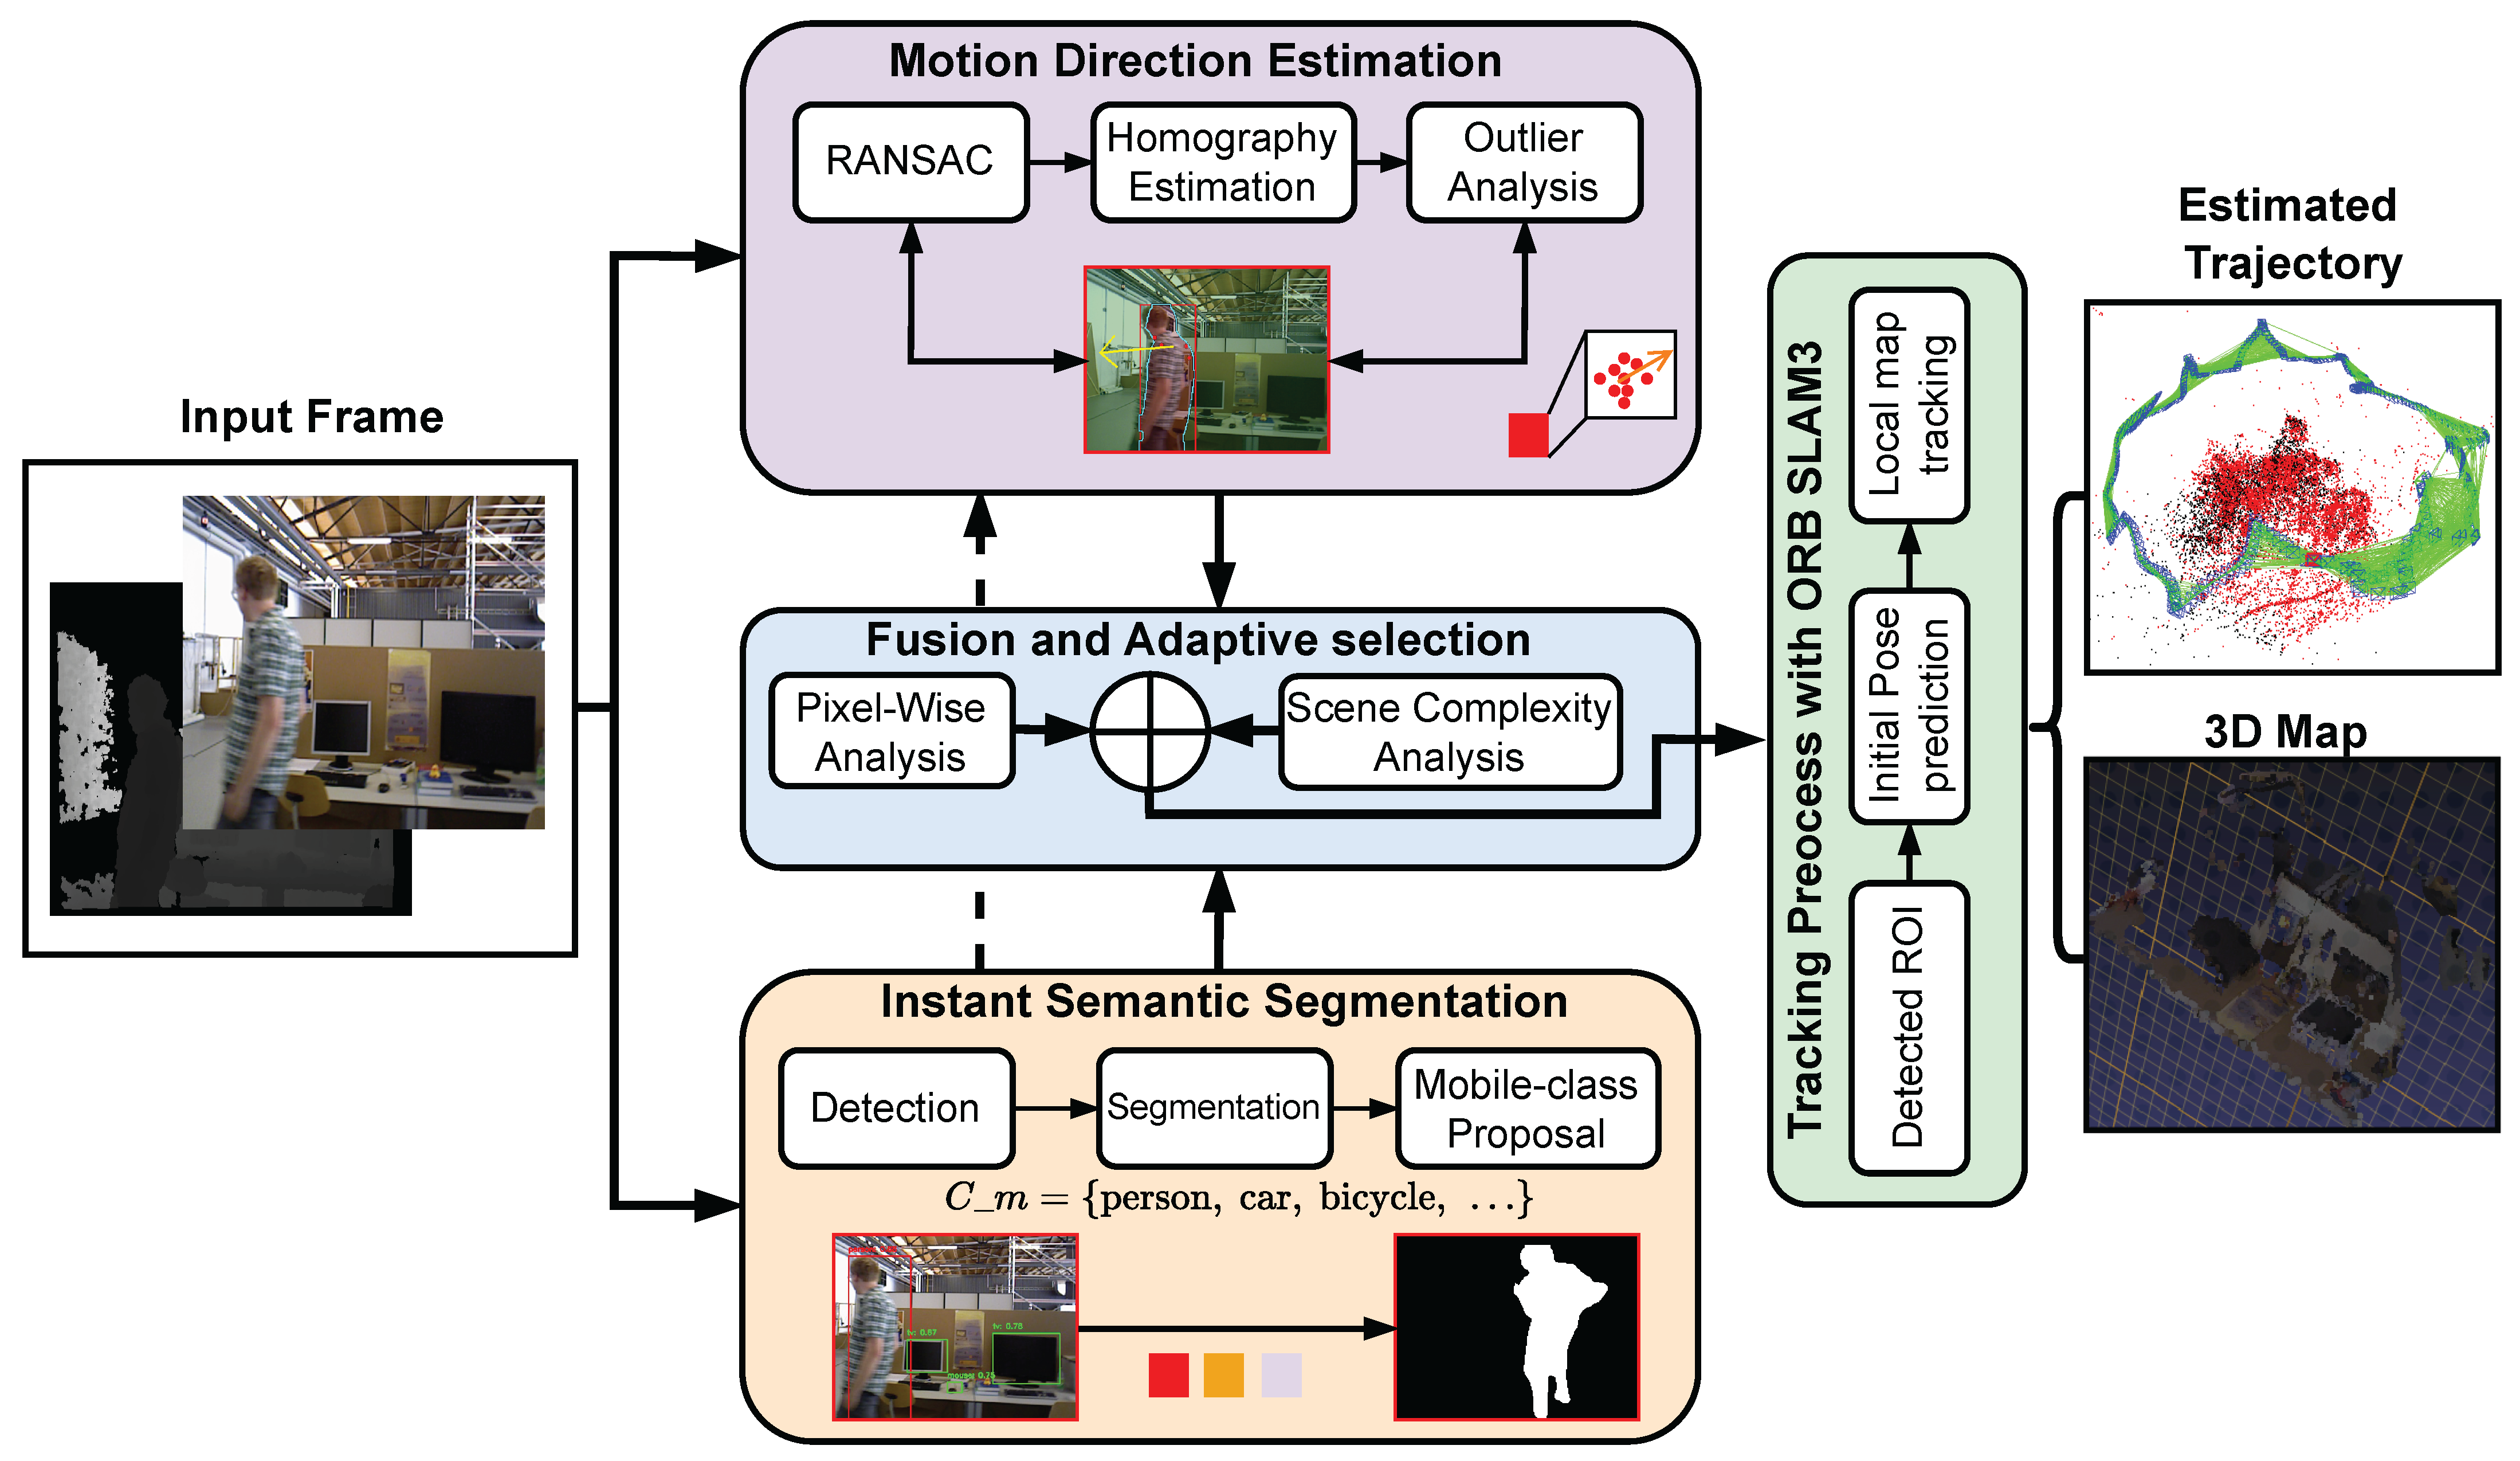
SAR-SLAM is an RGB-D SLAM framework that revisits the handling of dynamic objects for robust robot navigation in human-populated environments. It combines semantic detection with geometric verification to distinguish truly moving objects from stationary ones: YOLOv8 identifies candidate dynamic regions, while RANSAC-based homography verification confirms genuine motion, and an adaptive fusion strategy maintains tracking stability. Evaluated on the TUM RGB-D benchmarks, SAR-SLAM reduces Absolute Trajectory Error by up to 96% compared to ORB-SLAM3 in dynamic scenes.
Fulltext Access
https://doi.org/10.3390/robotics15070136
Citing
@article{altawil2026sarslam,
  title={SAR-SLAM: Semantic-Aware Recognition for Dynamic SLAM in Robotic Applications},
  author={Al-Tawil, Basheer and Jung, Magnus and Hempel, Thorsten and Al-Hamadi, Ayoub},
  journal={Robotics},
  volume={15},
  number={7},
  pages={136},
  year={2026},
  publisher={MDPI}
}