SEMIAC: A Two-Site Human-Robot Collaboration Dataset for Exploring Socially-Enriched Models for Implicit Action Coordination
A multimodal dataset of human-robot interactions collected with a Wizard-of-Oz methodology across a logistics-inspired workspace and a home environment, capturing behavioural, emotional, proxemic, and subjective responses during cooperative object-retrieval tasks with systematically manipulated robot errors.
SEMIAC: A Two-Site Human-Robot Collaboration Dataset for Exploring Socially-Enriched Models for Implicit Action Coordination
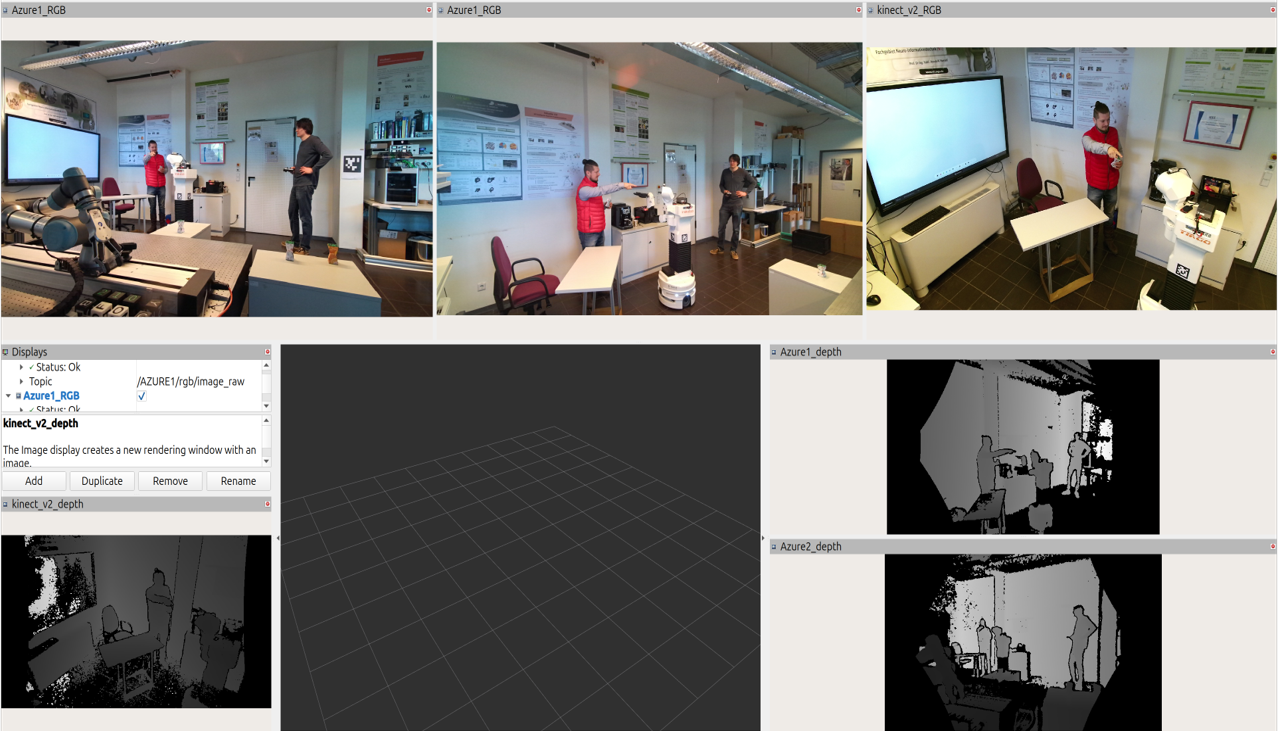
We present SEMIAC, a multimodal dataset of human-robot interactions (HRI) collected with a Wizard-of-Oz methodology in a logistics-inspired workspace and a home environment. The dataset includes 40 participants across two research sites and captures their behavioural, emotional, proxemic, and subjective responses during cooperative object-retrieval tasks with systematically manipulated robot errors. Interactions were recorded using a rich sensor suite including the humanoid robot TIAGo equipped with onboard sensors and an RGB-D camera, as well as three external RGB-D sensors, and an external microphone. All modalities were recorded fully synchronized through ROS and stored in time-aligned rosbag files. Annotations include human keypoints, proxemic distances, emotional expressions, and engagement indicators. The dataset aims to support research on social navigation, error-aware intent prediction, and socially intelligent robot behaviour.
Fulltext Access
https://doi.org/10.1145/3776734.3794550
Citing
@inproceedings{jung2026semiac,
  title={SEMIAC: A Two-Site Human-Robot Collaboration Dataset for Exploring Socially-Enriched Models for Implicit Action Coordination},
  author={Jung, Magnus and Yang, Qiaoyue and von Seelstrang, Leander and Strazdas, Dominykas and Wachsmuth, Sven and Al-Hamadi, Ayoub},
  booktitle={Companion of the 2026 ACM/IEEE International Conference on Human-Robot Interaction},
  year={2026},
  organization={ACM/IEEE}
}