News
News & blog posts
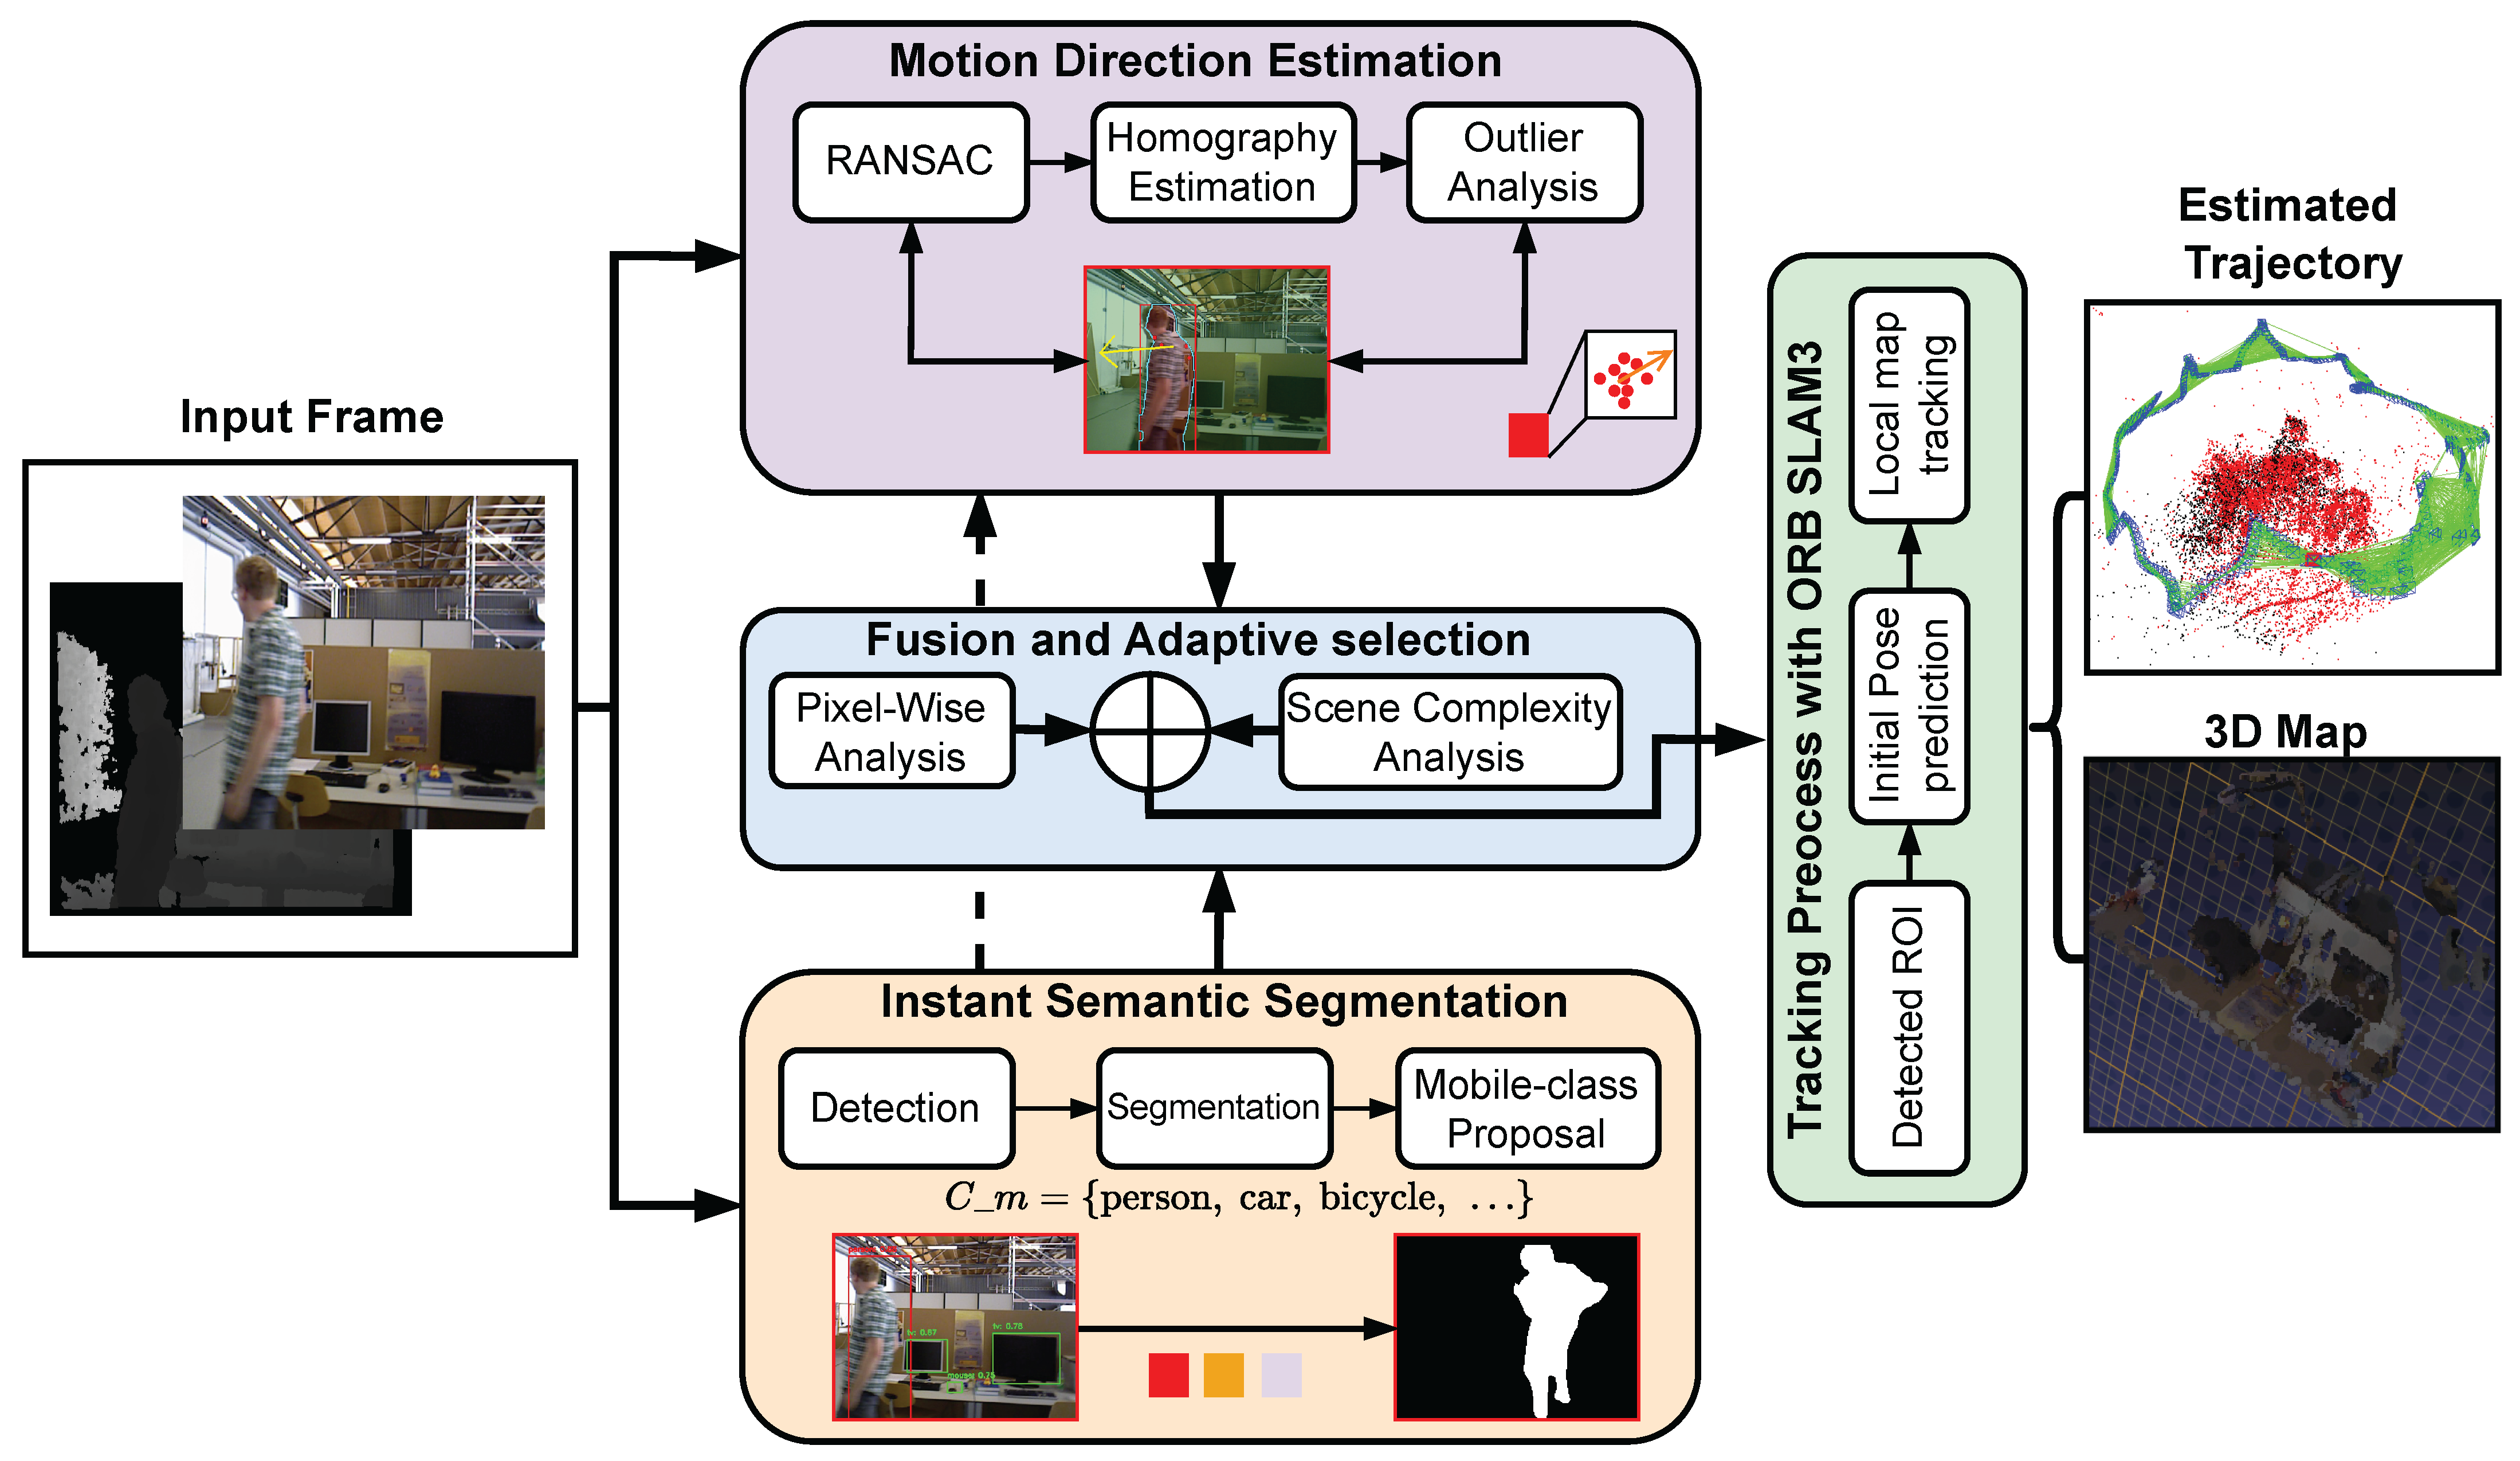
SAR-SLAM: Semantic-Aware Recognition for Dynamic SLAM in Robotic Applications
July 20, 2026
SAR-SLAM is an RGB-D SLAM framework that combines semantic detection with geometric verification to distinguish stationary from moving objects, reducing...
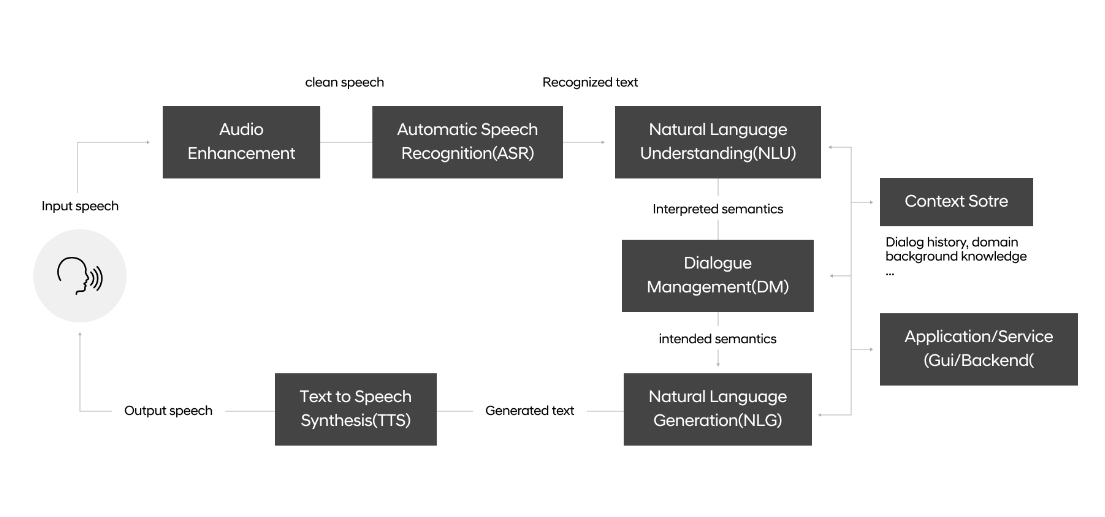
Intent Recognition in Speech-to-Text Processing in the Context of Natural Interaction with Cognitive Assistive Systems
May 13, 2026
A study of speech-to-intent recognition for human-robot interaction in elderly-care environments in German, deployed on resource-constrained platforms, comparing a modular...
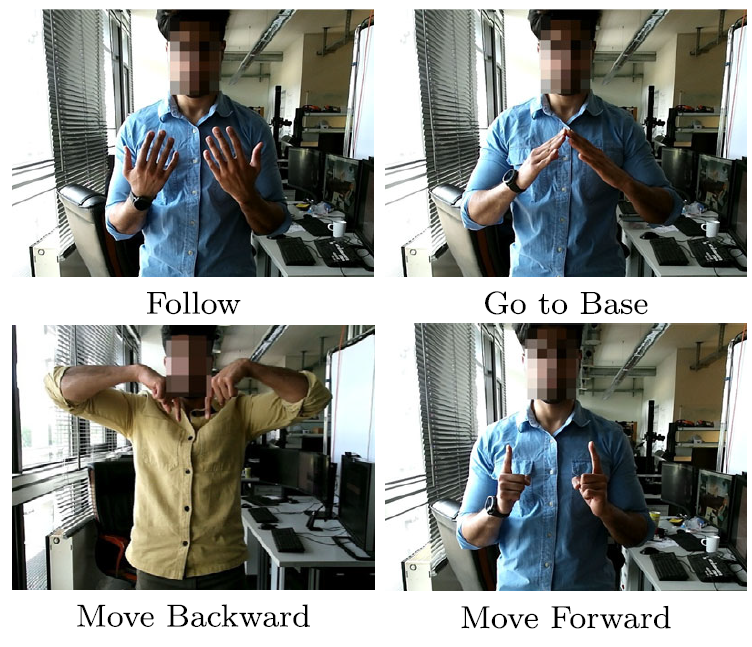
GESTRO: Skeleton-Based Dynamic Gesture Recognition for Robot Teleoperation
April 16, 2026
GESTRO introduces a dataset of 11 dynamic gestures with 3,300 samples for intuitively controlling mobile autonomous systems, together with an...
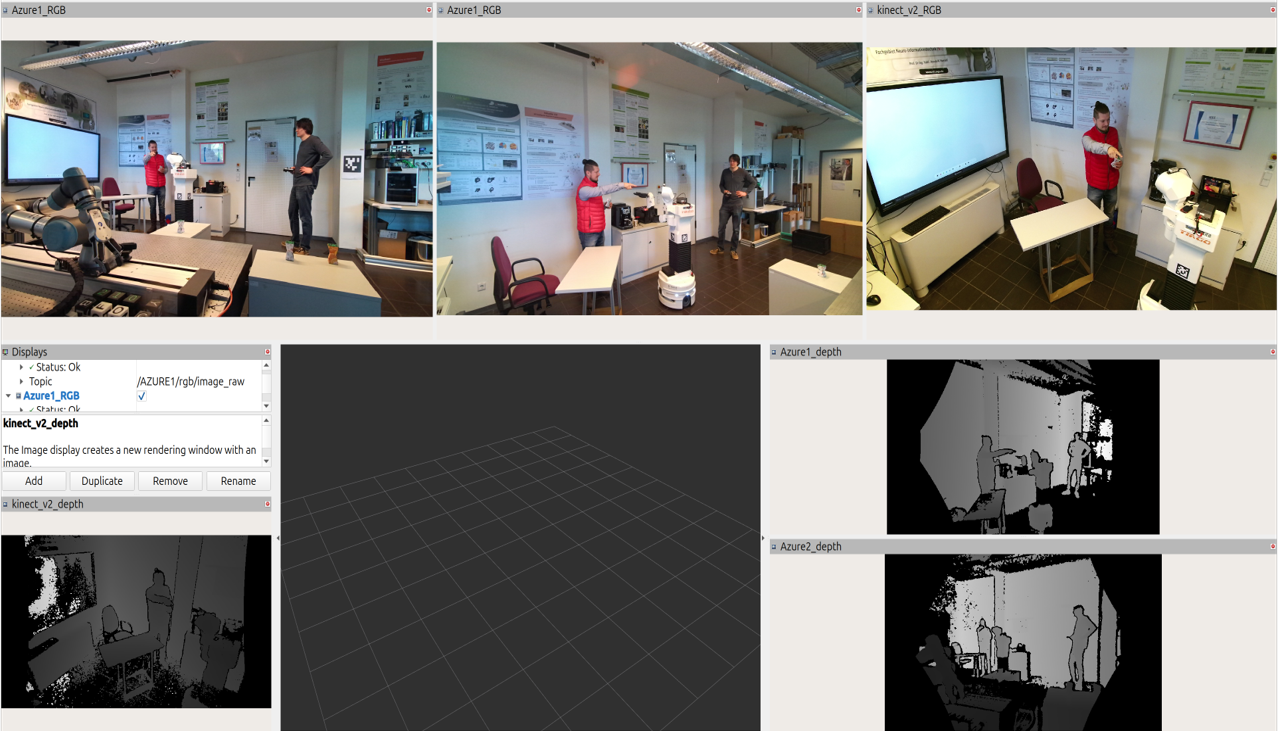
SEMIAC: A Two-Site Human-Robot Collaboration Dataset for Exploring Socially-Enriched Models for Implicit Action Coordination
March 16, 2026
A multimodal dataset of human-robot interactions collected with a Wizard-of-Oz methodology across a logistics-inspired workspace and a home environment, capturing...
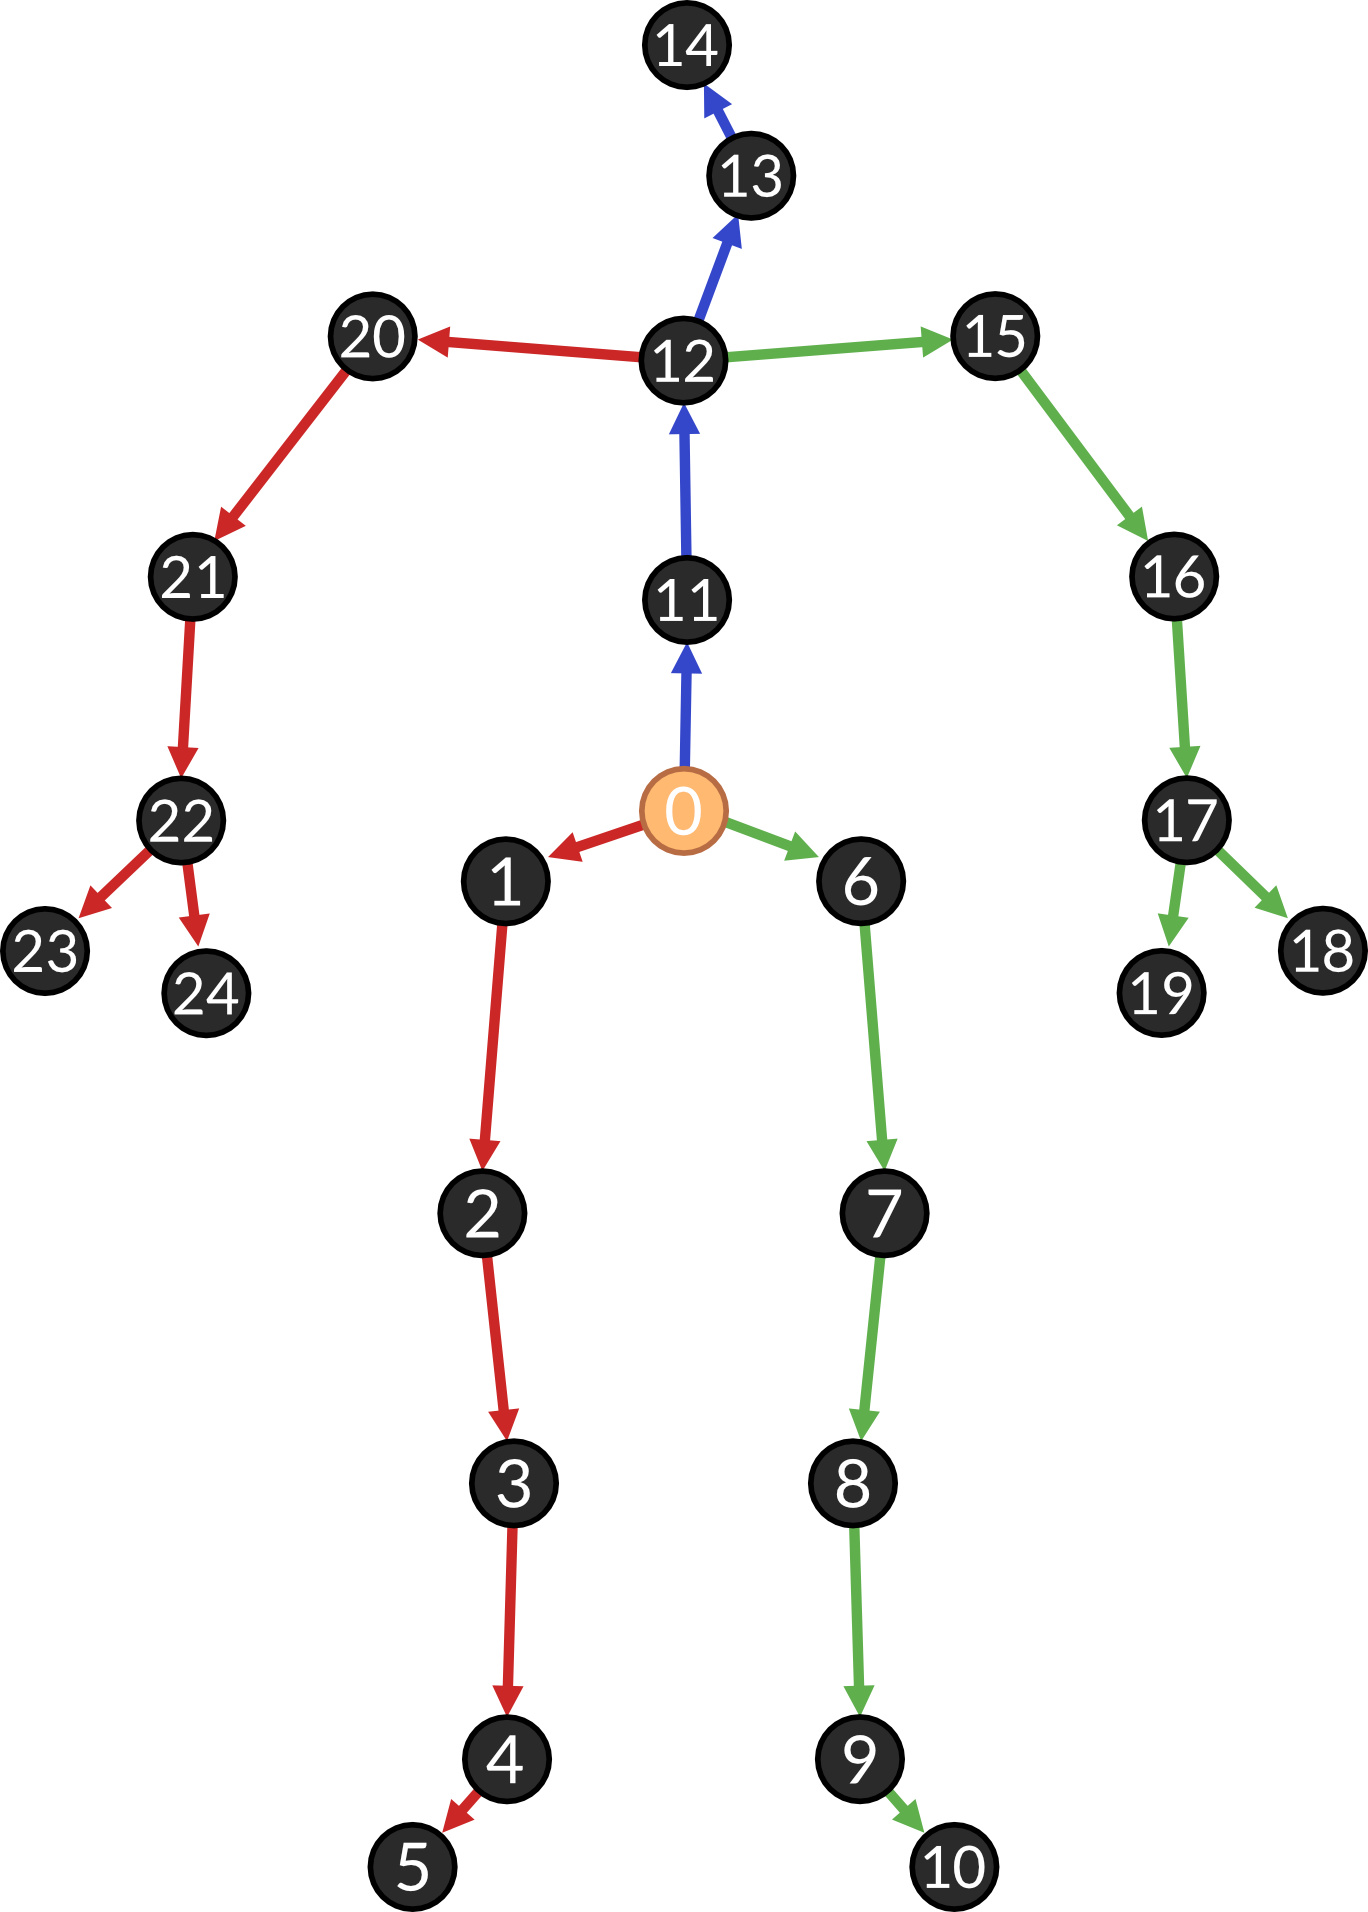
Long-Term Prediction of Local and Global Human Motion with Occlusion Recovery
November 17, 2025
A non-autoregressive transformer based on spatio-temporal attention, trained for both local pose anticipation and global motion prediction in space, while...
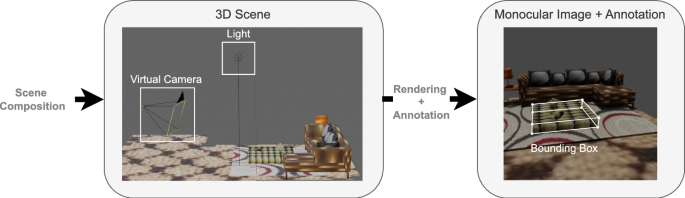
Automating Synthetic Dataset Generation for Image-Based 3D Detection: A Literature Review
November 13, 2025
Reliable 3D detection is fundamental to autonomous systems such as mobile robots, self-driving cars, and UAVs. This literature review categorizes...

Automated 3D Dataset Generation for Arbitrary Objects
October 06, 2025
6D pose estimation is a cornerstone of various autonomous systems, including mobile robots and self-driving cars, because it enables fundamental...
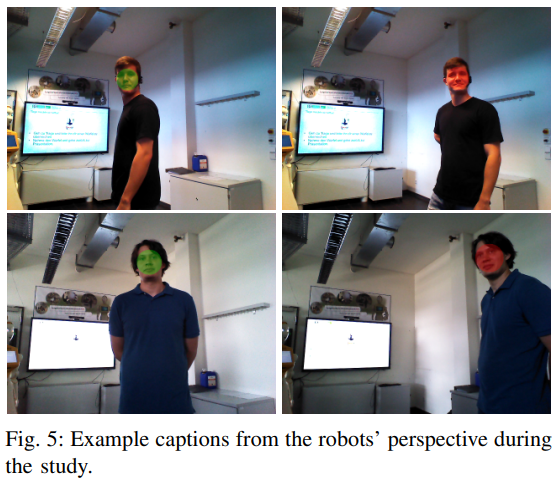
Gaze Matters: Eye Contact Detection in Unscripted Human-Robot Interaction Scenarios
October 05, 2025
A user study in a realistic collaborative HRI scenario with unscripted tasks evaluates the performance of current eye contact detection...
Scene-Aware Prediction of Diverse Human Movement Goals
October 01, 2025
Anticipation of human behaviours facilitates autonomous systems in proactive planning. Human behaviour could be stochastic due to varying goals. Human...
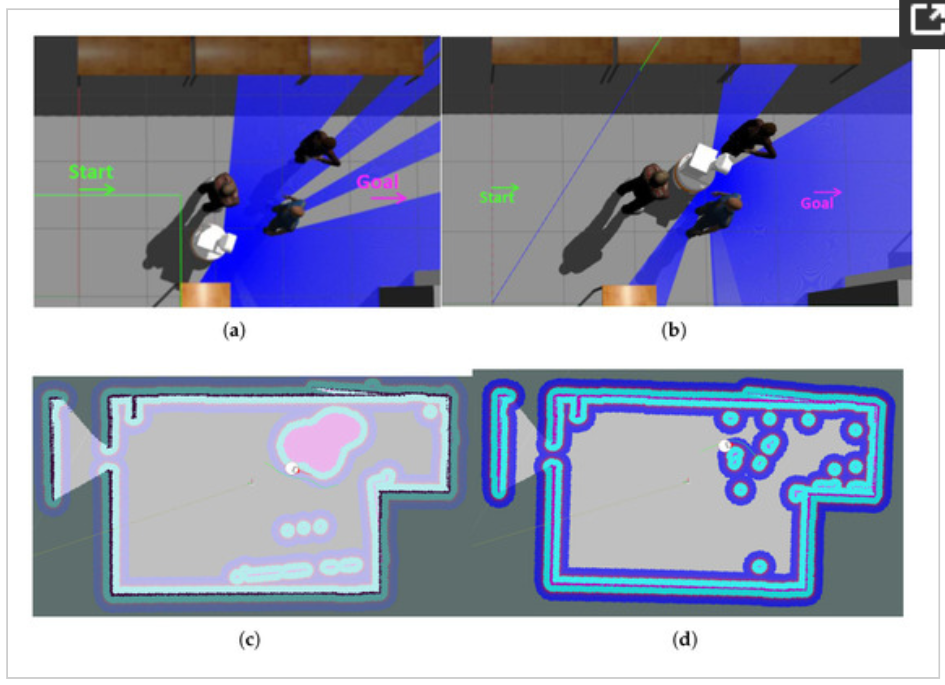
Learning Human–Robot Proxemics Models from Experimental Data
September 18, 2025
Humans in a society generally tend to implicitly adhere to the shared social norms established within that culture. Robots operating...
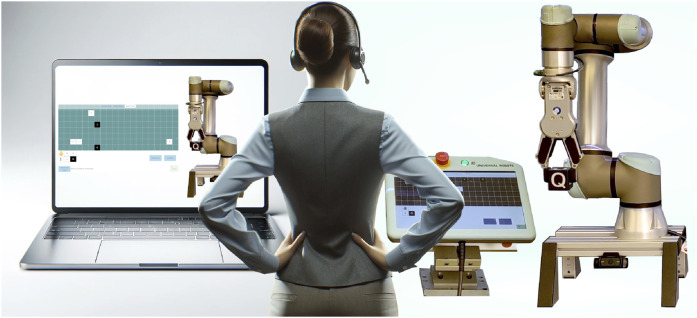
Robot System Assistant (RoSA) evaluation of touch and speech input modalities for on-site HRI and telerobotics
June 30, 2025
As humans and robots collaborate more in industrial settings, flexible interaction modalities become essential. This study evaluates a hybrid interaction...
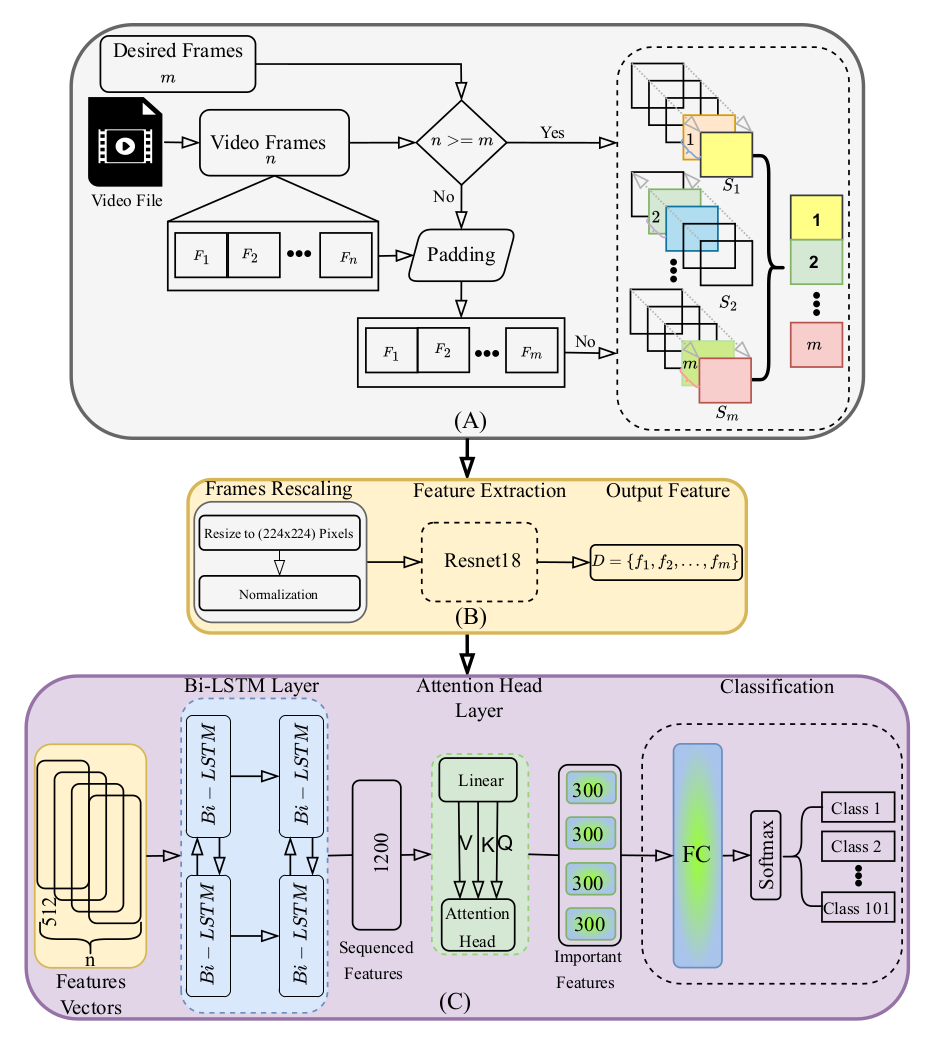
Multi-Head Attention-Based Framework with Residual Network for Human Action Recognition
May 06, 2025
We propose a novel HAR framework integrating residual networks, Bi-LSTM, and multi-head attention with a motion-based frame selection strategy. It...
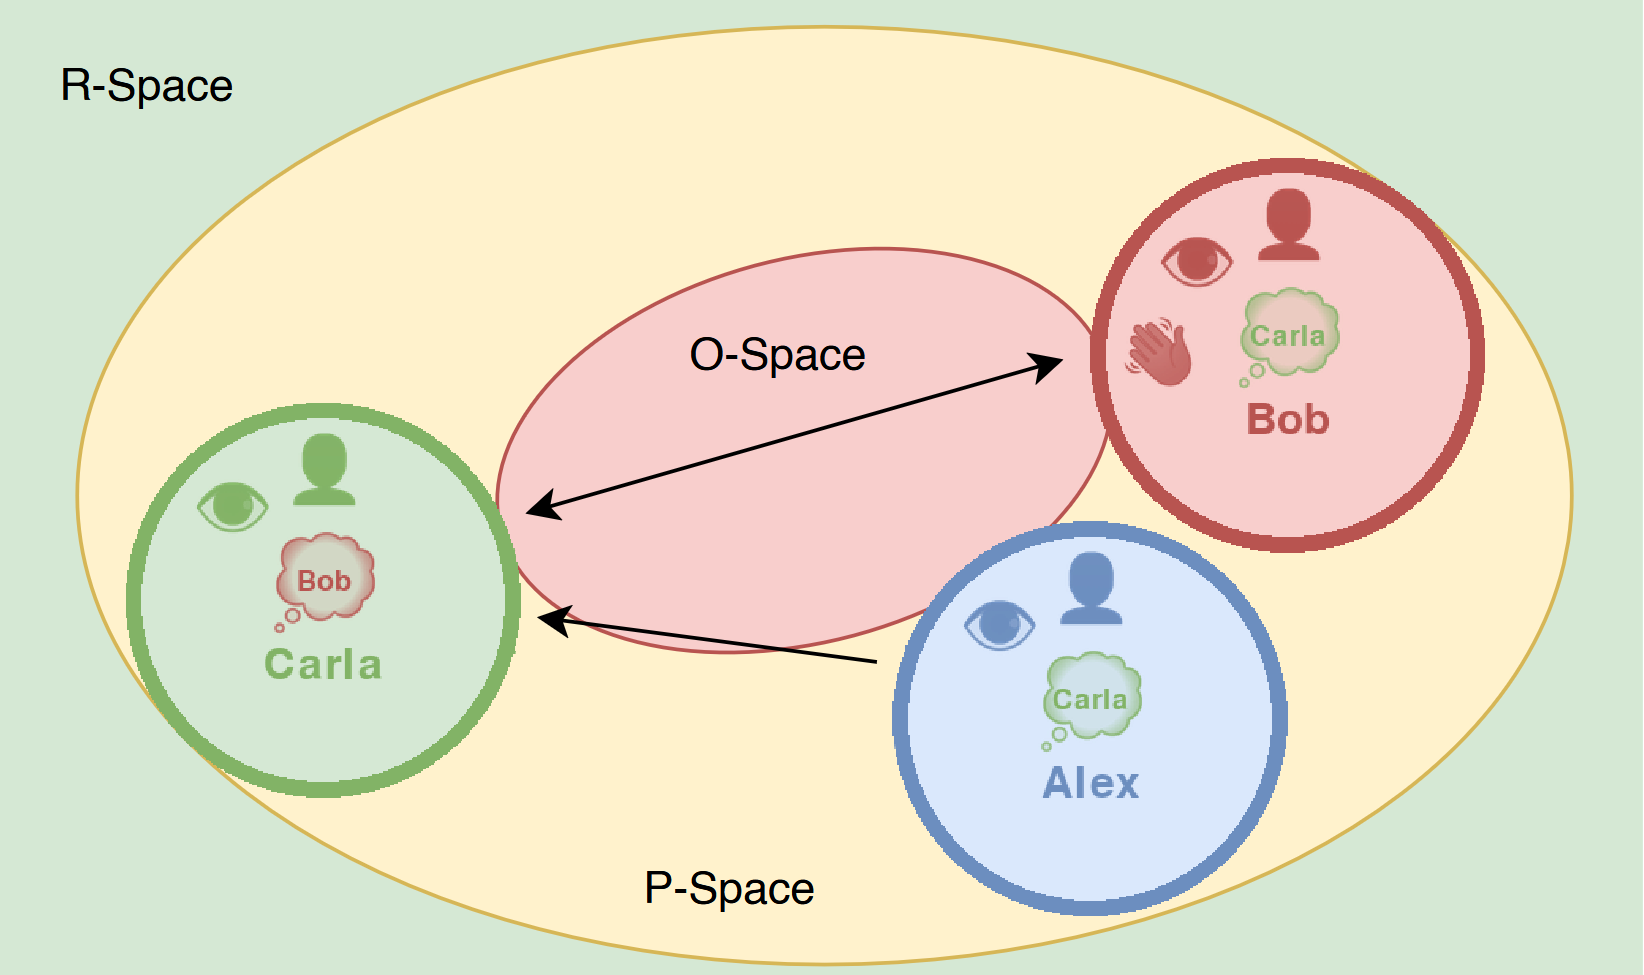
IM HERE – Interaction Model for Human Effort based Robot Engagement
April 29, 2025
We present our novel engagement modeling framework IMHERE, designed to improve human-robot interaction by capturing relational dynamics using a formal...
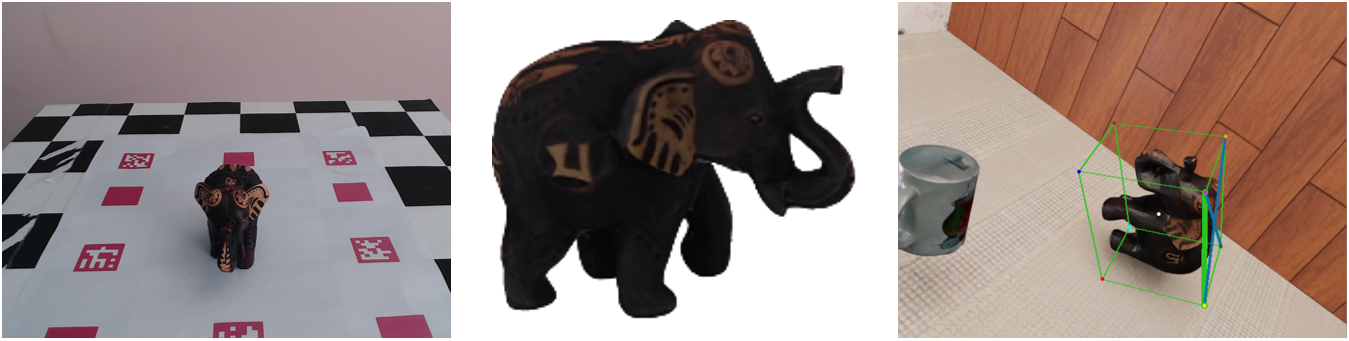
Automating 3D Dataset Generation with Neural Radiance Fields
April 29, 2025
We present a fully automated pipeline that leverages Radiance Field–based universal 3D representations to rapidly generate high-quality models of arbitrary...
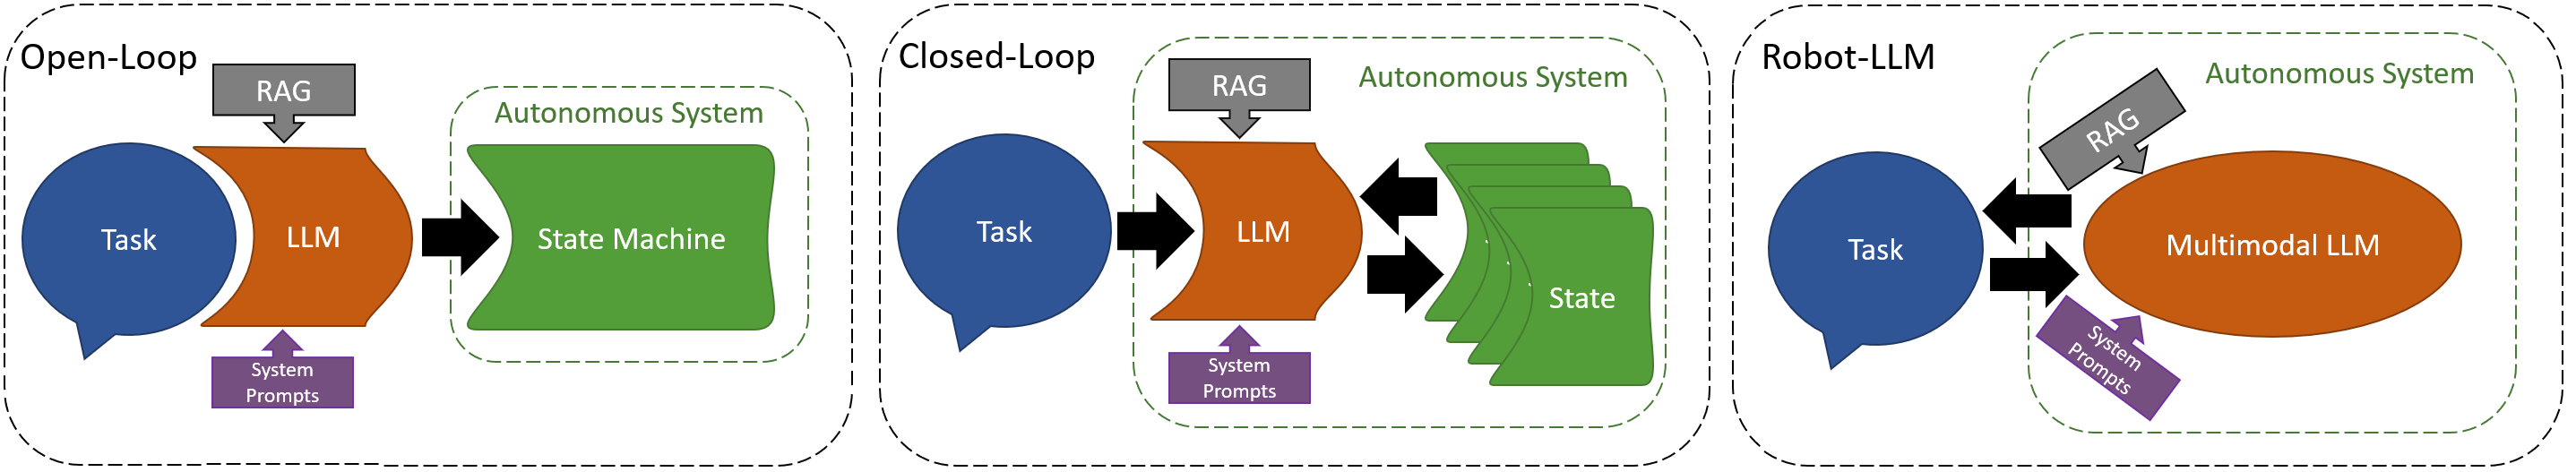
Toward Truly Intelligent Autonomous Systems A Taxonomy of LLM Integration for Everyday Automation
April 28, 2025
With the rapid development of large language models (LLMs), their integration into autonomous systems has become essential. This integration significantly...
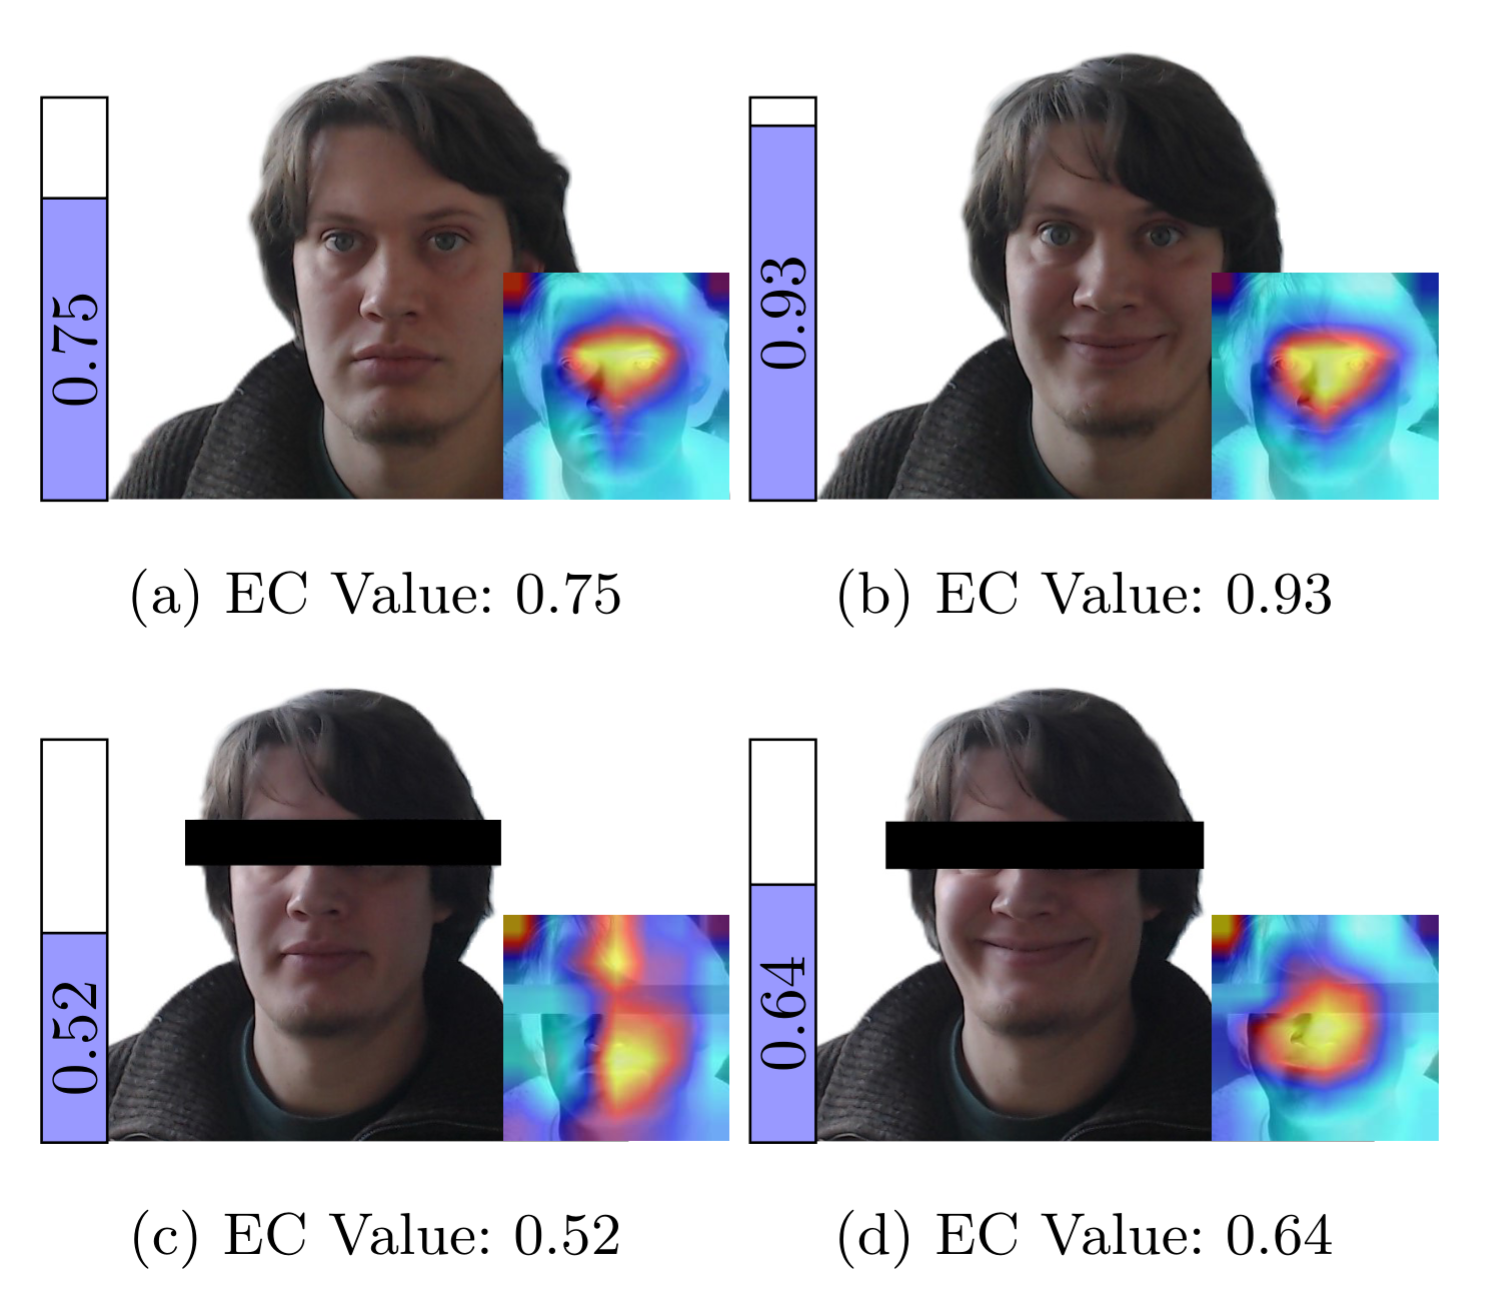
Eye Contact Based Engagement Prediction for Efficient Human-Robot Interaction
April 28, 2025
We introduce a new approach to predict human engagement in human-robot interactions (HRI), focusing on eye contact and distance information....
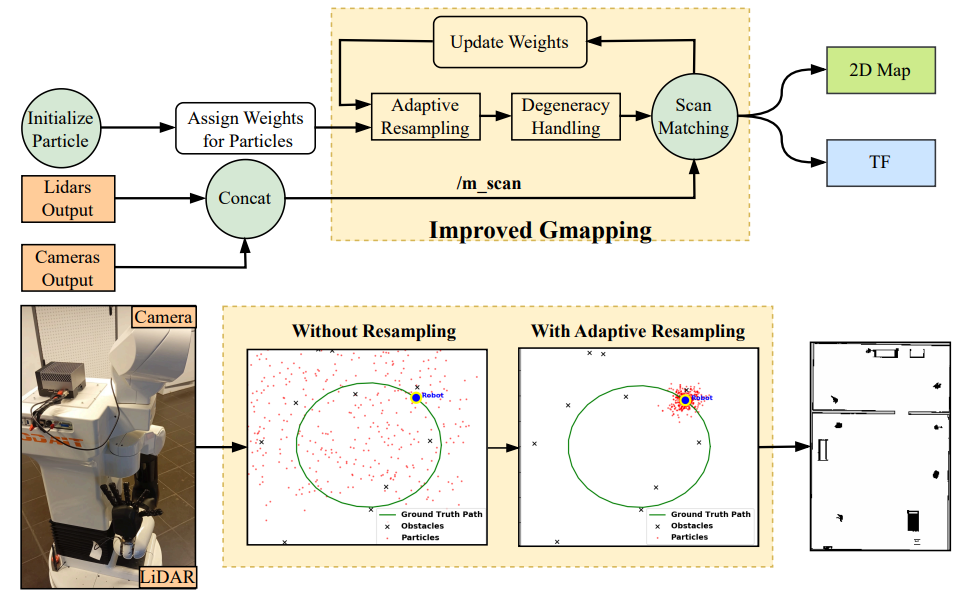
Mobile Robot Navigation with Enhanced 2D Mapping and Multi-Sensor Fusion
April 10, 2025
We propose an enhanced SLAM framework that combines RGB-D and 2D LiDAR data using late fusion and adaptive resampling for...
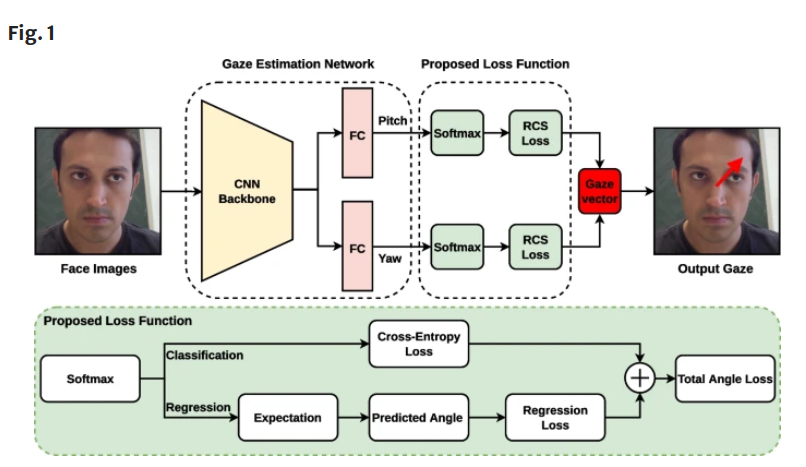
Fine-grained gaze estimation based on the combination of regression and classification losses
September 03, 2024
We present our recent work on gaze estimation. Our approach is a novel two-branch CNN architecture with a multi-loss approach...